I'm with about 25 people in a hotel in the New Forest to talk about the ethical, legal and societal issues around robotics. We are a diverse crew: a core of robotics and AI folk, richly complemented by academics in psychology, law, ethics, philosophy, culture, performance and art history. This joint EPSRC/AHRC workshop was an outcome of a discussion on robot ethics at the EPSRC Societal Issues Panel in November 2009. (See also my post The Ethical Roboticist.)
Of course in any discussion about robot ethics it is inevitable that Asimov's Three Laws of Robotics will come up and, I must admit, I've always insisted that they have no value whatsoever. They were, after all, a fictional device for creating stories with dramatic moral ambiguities - not a serious attempt to draw up a moral code of robots. Today I've been forced to revise that opinion. Amazingly we have succeeded in drafting a new set of five 'laws', not for robots themselves but for designers and operators of robots. (You can't have laws for robots because they are not persons - or at least not for the foreseeable future.)
I can't post them here just yet - a joint statement needs to be drafted and agreed first. But to answer the question in the title of this post - no, robots can't be Three Laws Safe, but they quite possibly could be Five Laws Compliant.
Postscript: here is a much better description of the workshop on Lilian Edwards' excellent blog.
Thursday, September 30, 2010


Tuesday, September 28, 2010
Robot imitation as a method for modelling the foundations of social life
Robot imitation as a method for modelling the foundations of social life: a meeting of robotics and sociology to explore the spread of behaviours through mimesis
Here is the video, posted earlier this month by Frances Griffiths on YouTube, of the meeting of robotics and sociology I blogged about on 21st June. No need for me to write anything more - Roger Stotesbury's excellent 10 minute film explains the whole thing...
Here is the video, posted earlier this month by Frances Griffiths on YouTube, of the meeting of robotics and sociology I blogged about on 21st June. No need for me to write anything more - Roger Stotesbury's excellent 10 minute film explains the whole thing...
Friday, September 10, 2010
Morphogenetic Engineering at ANTS
I'm at the excellent Swarm Intelligence conference in Brussels, called appropriately ANTS. This morning there is a special session on morphogenetic engineering, chaired by René Doursat, of the complex systems institute in Paris. Morphogenetic engineering is the name coined for a new cross over between biology and engineering. Current engineered systems are designed and 'built'. Biological systems on the other hand grow from seeds or embryos. Morphogenetic engineering asks the question, might it be possible to 'grow' complex engineered systems, like robots?
Of course with current materials: metal and plastic, we can't grow robots so many of the ideas of morphogenetic engineering remain, for the time being, future concepts. But I think we'll see some exciting developments in this new sub-field as new materials become available.
Here is an image from our talk* on autonomous distributed morphogenesis in the Symbrion project, presented during the special session. Here you see robots being recruited to join the 2D planar organism during its formation.

* Wenguo Liu and Alan FT Winfield, 'Autonomous morphogenesis in self-assembling robots using IR-based sensing and local communications', ANTS 2010.
Of course with current materials: metal and plastic, we can't grow robots so many of the ideas of morphogenetic engineering remain, for the time being, future concepts. But I think we'll see some exciting developments in this new sub-field as new materials become available.
Here is an image from our talk* on autonomous distributed morphogenesis in the Symbrion project, presented during the special session. Here you see robots being recruited to join the 2D planar organism during its formation.

* Wenguo Liu and Alan FT Winfield, 'Autonomous morphogenesis in self-assembling robots using IR-based sensing and local communications', ANTS 2010.
Wednesday, September 08, 2010
Darn - conference paper soundly rejected
As someone who believes in - and from time-to-time advocates - the Open Science approach, I need to practise what I preach. That means being open about the things that don't go according to plan in a research project - including when papers that you think are really great get rejected following peer review. So, let me 'fess up. A paper I submitted to the highly regarded conference Distributed Autonomous Robotic Systems, describing results from the Artificial Culture project, has just been soundly rejected by the reviewers.
Of course, having papers rejected is not unusual. And, like most academics, I tend to react with indignation ("how dare they"), dismissal ("the reviewers clearly didn't understand the work") and embarrassment (hangs head in shame). After a day or two the first two feelings subside, but the embarrassment remains. None of us likes it when our essays come back marked C-. That is why this blog post is not especially comfortable to write.
My paper had four anonymous reviews, and each one was thorough and thoughtful. And - although not all reviewers recommended rejection - the overall verdict to reject was, in truth, fully justified. The paper, titled A Multi-robot Laboratory for Experiments in Embodied Memetic Evolution failed to either fully describe the laboratory, or the experiments. Like most conference papers there was a page limit (12 pages) and I tried to fit too much into the paper.
So, what next for this paper? Well the work will not be wasted. We shall revise the paper - taking account of the reviewers comments - and submit it elsewhere. So, despite my embarrassment, I am grateful to those reviews (I don't know who you are but if you should read this blog - thank you!).
And for Open Science. Well, a fully paid-up card carrying Open Scientist would publish here the original paper and the reviews. But it seems to me improper to publish the reviews without first getting the reviewers' permission - and I can't do that because I don't know who they are. And I shouldn't post the paper either, since to do so would compromise our ability to submit the same work (following revision) somewhere else. So Open Science, even with the best of intentions, has its hands tied by publications protocols.
Of course, having papers rejected is not unusual. And, like most academics, I tend to react with indignation ("how dare they"), dismissal ("the reviewers clearly didn't understand the work") and embarrassment (hangs head in shame). After a day or two the first two feelings subside, but the embarrassment remains. None of us likes it when our essays come back marked C-. That is why this blog post is not especially comfortable to write.
My paper had four anonymous reviews, and each one was thorough and thoughtful. And - although not all reviewers recommended rejection - the overall verdict to reject was, in truth, fully justified. The paper, titled A Multi-robot Laboratory for Experiments in Embodied Memetic Evolution failed to either fully describe the laboratory, or the experiments. Like most conference papers there was a page limit (12 pages) and I tried to fit too much into the paper.
So, what next for this paper? Well the work will not be wasted. We shall revise the paper - taking account of the reviewers comments - and submit it elsewhere. So, despite my embarrassment, I am grateful to those reviews (I don't know who you are but if you should read this blog - thank you!).
And for Open Science. Well, a fully paid-up card carrying Open Scientist would publish here the original paper and the reviews. But it seems to me improper to publish the reviews without first getting the reviewers' permission - and I can't do that because I don't know who they are. And I shouldn't post the paper either, since to do so would compromise our ability to submit the same work (following revision) somewhere else. So Open Science, even with the best of intentions, has its hands tied by publications protocols.
Tuesday, August 24, 2010
On The Human on Temes: an emerging third replicator
Several weeks ago I was contacted by On The Human, a forum for researchers across science and the humanities to share ideas, and asked if I would like to take part in an online debate in response to an essay by Susan Blackmore. The forum runs one of these debates every two weeks and there are some pretty interesting writers and debates (which - it seems - are moderated and time limited).
So, I looked out for Sue's essay, which appeared yesterday 23rd August. I thought about it (actually had a head start because we had debated temes during a memelab meeting) and posted my response this morning. Here is Sue's essay Temes: An Emerging Third Replicator, the collected comments, and Sue's responses to those comments.
So, I looked out for Sue's essay, which appeared yesterday 23rd August. I thought about it (actually had a head start because we had debated temes during a memelab meeting) and posted my response this morning. Here is Sue's essay Temes: An Emerging Third Replicator, the collected comments, and Sue's responses to those comments.
Friday, August 20, 2010
Open-hardware Linux e-puck extension board published
It's now over two years since I first blogged about our Linux-enhanced e-puck, designed by my colleague Dr Wenguo Liu. Since then, the design has gone through several improvements and is now very stable and reliable. We've installed the board on all 50 of our e-puck robots and it has also been adopted for use in swarm robotics projects by Jenny Owen at York, Andy Guest at Abertay Dundee and Newport.
Since the e-puck robot is open-hardware, Wenguo and I were keen that our extension board should follow the same principle, and so the complete design has been published online at sourceforge here http://lpuck.sourceforge.net/. All of the hardware designs, together with code images and an excellent installation manual written by Jean-Charles Antonioli are here.

Here's a picture of the extension board. The big chip is an ARM9 microcontroller and the small board hanging off some wires is the WiFi card (in fact it's a WiFi USB stick with the plastic casing removed).
 And here is a picture of one of our e-pucks with the Linux extension board fitted, just above the red skirt. The WiFi card is now invisible because it is fitted neatly into a special slot on the underside of the yellow 'hat'.
The main function of the yellow hat is the matrix of pins on the top, that we use for the reflective spheres needed by our Vicon tracking system to track the exact position of each robot during experiments. You can see one of the spheres very strongly reflecting the camera flash in this photo. The function of the red skirt is so that robots can see each other, with their onboard cameras. You can see the camera in the small hole in the middle of the red skirt. Without the red skirt the robots simply don't see each other too well, at least partly because of their transparent bodies.
postscript (added Feb 2011): Here's the reference to our paper describing the extension board:
Liu W, Winfield AFT, 'Open-hardware e-puck Linux extension board for experimental swarm robotics research', Microprocessors and Microsystems, 35 (1), 2011, doi:10.1016/j.micpro.2010.08.002.
Since the e-puck robot is open-hardware, Wenguo and I were keen that our extension board should follow the same principle, and so the complete design has been published online at sourceforge here http://lpuck.sourceforge.net/. All of the hardware designs, together with code images and an excellent installation manual written by Jean-Charles Antonioli are here.

Here's a picture of the extension board. The big chip is an ARM9 microcontroller and the small board hanging off some wires is the WiFi card (in fact it's a WiFi USB stick with the plastic casing removed).
 And here is a picture of one of our e-pucks with the Linux extension board fitted, just above the red skirt. The WiFi card is now invisible because it is fitted neatly into a special slot on the underside of the yellow 'hat'.
The main function of the yellow hat is the matrix of pins on the top, that we use for the reflective spheres needed by our Vicon tracking system to track the exact position of each robot during experiments. You can see one of the spheres very strongly reflecting the camera flash in this photo. The function of the red skirt is so that robots can see each other, with their onboard cameras. You can see the camera in the small hole in the middle of the red skirt. Without the red skirt the robots simply don't see each other too well, at least partly because of their transparent bodies.
postscript (added Feb 2011): Here's the reference to our paper describing the extension board:
Liu W, Winfield AFT, 'Open-hardware e-puck Linux extension board for experimental swarm robotics research', Microprocessors and Microsystems, 35 (1), 2011, doi:10.1016/j.micpro.2010.08.002.
Saturday, July 17, 2010
Open-ended Memetic Evolution, or is it?
Just finished a paper describing some new results on open-ended memetic evolution from the Artificial Culture project. I describe in some detail one particular experiment in which 2 robots imitate each others' movements. However, here the robots don't simply imitate the last thing they saw; instead they learn and save every observed movement sequence, then when it's a robot's turn to dance it selects one of its 'learned' dances, from memory, at random.
Here is a plot of the movements of the 2 robots for one particular experiment; this picture has been generated by a tool developed by Wenguo Liu that allows us to 'play back' the tracking data recorded by the Vicon position tracking system. The visualisation tool changes the colour of each 'dance', which makes it much easier to then analyse what's going on during the experiment.

Epuck 9 (on the left) starts by making a 3 sided 'triangle' dance, numbered 1 above. Epuck 12 (on the right) then imitates this - badly - as meme number 2, which is a kind of figure-of-8 pattern. It is interesting to see that this 4-sided figure-of-8 movement pattern then appears to become dominant, perhaps because of the initially poor fidelity imitation (1 → 2), then the high fidelity imitation of 2 by epuck9 (2 → 3), then the re-enaction of meme 2 as meme 4. And then subsequent copies of the same figure-of-8 meme then appear to be reasonably good copies, which reinforces the dominance of that meme.
Since the robots are selecting which observed and learned meme to enact, at random, then there is no 'direction' to the meme evolution here. Memes can get longer or shorter - both in the number of sides to the movement pattern, and the length of those sides, and the resulting patterns arise in an unpredictable way from the imperfect 'embodied' imitation of the robots. Thus, we appear to have demonstrated here, open-ended memetic evolution.
Here is a screen captured low-resolution (sorry) movie of the sequence:
Here is a plot of the movements of the 2 robots for one particular experiment; this picture has been generated by a tool developed by Wenguo Liu that allows us to 'play back' the tracking data recorded by the Vicon position tracking system. The visualisation tool changes the colour of each 'dance', which makes it much easier to then analyse what's going on during the experiment.

Epuck 9 (on the left) starts by making a 3 sided 'triangle' dance, numbered 1 above. Epuck 12 (on the right) then imitates this - badly - as meme number 2, which is a kind of figure-of-8 pattern. It is interesting to see that this 4-sided figure-of-8 movement pattern then appears to become dominant, perhaps because of the initially poor fidelity imitation (1 → 2), then the high fidelity imitation of 2 by epuck9 (2 → 3), then the re-enaction of meme 2 as meme 4. And then subsequent copies of the same figure-of-8 meme then appear to be reasonably good copies, which reinforces the dominance of that meme.
Since the robots are selecting which observed and learned meme to enact, at random, then there is no 'direction' to the meme evolution here. Memes can get longer or shorter - both in the number of sides to the movement pattern, and the length of those sides, and the resulting patterns arise in an unpredictable way from the imperfect 'embodied' imitation of the robots. Thus, we appear to have demonstrated here, open-ended memetic evolution.
Here is a screen captured low-resolution (sorry) movie of the sequence:
Monday, June 21, 2010
Warwick Mimesis project visit to the lab
As a follow-up to a talk I gave last December in Warwick, we were visited in the lab today by a group of social and complexity scientists from Warwick including Frances Griffiths, Steve Fuller and Nick Lee. We had a hugely interesting day discussing the extent to which (or, indeed, if at all) robots could be used to model mimesis in society.
The day started with me describing the embodied imitation-of-movement experiments that we are currently doing here within the Artificial Culture project, and demonstrating the latest version of the Copybots experiment. After lunch we then had a round table discussion about whether or not such a simple model might have value in social science research and - somewhat to my surprise - there seemed to be strong consensus that there is value and that this (radical) new approach to embodied modelling is something we should actively pursue in future joint projects.
The meeting was filmed by Roger Stotesbury of Jump Off The Screen and I hope to post a link to the video record of the meeting on this blog.
Postscript: here is my blog post with Roger's film of the meeting.
The day started with me describing the embodied imitation-of-movement experiments that we are currently doing here within the Artificial Culture project, and demonstrating the latest version of the Copybots experiment. After lunch we then had a round table discussion about whether or not such a simple model might have value in social science research and - somewhat to my surprise - there seemed to be strong consensus that there is value and that this (radical) new approach to embodied modelling is something we should actively pursue in future joint projects.
The meeting was filmed by Roger Stotesbury of Jump Off The Screen and I hope to post a link to the video record of the meeting on this blog.
Postscript: here is my blog post with Roger's film of the meeting.
Tuesday, June 08, 2010
Walking with Robots wins Academy Award
No, not that academy, but an academy award all the same. Last night WWR won the Royal Academy of Engineering 2010 Rooke medal for the Public Promotion of Engineering. What can I say. It was wonderful for Walking with Robots to be recognised and acknowledged in this way. It was a great project. If there had been an acceptance speech we would have had a large number of thankyous: the EPSRC who funded WWR; the amazing WWR network of roboticists and engagers from about 12 universities and as many companies; Claire Rocks who - as brilliant WWR network coordinator - more than anyone made things happen, and of course the RAEng for this award. Thank you! And we had a wonderful evening.
Here we are receiving the award from Lord Browne (third from the left). On the left is Noel Sharkey and Owen Holland, and on the right me, Karen Bultitude and Claire Rocks.

Friday, June 04, 2010
Evolving e-pucks
 Nicolas Bredeche and his graduate student Jean-Marc Montanier have spent the last two weeks working in the lab to test out work they had already done in simulation, onto real robots. Nicolas is interested in evolutionary swarm robotics. This is an approach, inspired directly by Darwinian evolution, in which we do not design the robots' controllers (brains) but instead evolve them. In this case the brains are artificial neural networks and the process of artificial evolution evolves the strengths of the connections between the neurons. Nicolas is especially interested in open-ended evolution, in which he - as designer - does not pre-determine the evolved robot behaviours (by specifying an explicit fitness function, i.e. what kinds of behaviours the robots should evolve). Thus, even though this is an artificial system, its evolution is - in a sense - a bit closer to natural than artificial selection.
Friday, May 21, 2010
Real-world robotics reality check
This week's European Land Robotics trials (ELROB) in the beautiful countryside of Hammelburg provided the assembled roboticists with a salutary lesson in real world robotics. The harsh reality is that problems such as localisation, path planning and navigation, which most roboticists would regard as having been solved, remain very serious challenges in unstructured outdoor environments. Techniques that work perfectly in the lab, or the university car park, are very seriously challenged by a forest track in the rain or at night.
Having said that there were some deeply impressive demonstrations of fully autonomous operation by university teams - such as the University of Hannover's vehicle Hanna which deservedly took away one of the ELROB 2010 innovation awards. You're a robot: imagine having to navigate your way autonomously through several km of forest track at night; the only map you have is inaccurate and out of date and just 4 (GPS) waypoints are provided at the start of your 1 hour timeslot. There are no trial or practice runs for you to survey the track beforehand, and (just in case it might be too easy) there are unknown obstacles which require you to autonomously backtrack to the last fork and take an alternative route. A good indication of how tough this was is the fact that other (commercial) tele-operated robots, perhaps surprisingly, fared no better than their autonomous rivals. Having spent a cold couple of hours looking over the shoulders of 2 team members: one tele-operating his robot, the other (nervously) tracking his autonomous robot's progress on a laptop, it was clear to me that in an this environment tele-operation is - if anything - harder than autonomy. Or perhaps it would be fairer to say that neither tele-operation or autonomy is yet fully up to this kind of task.
I left ELROB wishing that my robotics research colleagues who never venture outside their labs could have witnessed this and, as I did, experience the harsh reality-check of real world robotics.
Having said that there were some deeply impressive demonstrations of fully autonomous operation by university teams - such as the University of Hannover's vehicle Hanna which deservedly took away one of the ELROB 2010 innovation awards. You're a robot: imagine having to navigate your way autonomously through several km of forest track at night; the only map you have is inaccurate and out of date and just 4 (GPS) waypoints are provided at the start of your 1 hour timeslot. There are no trial or practice runs for you to survey the track beforehand, and (just in case it might be too easy) there are unknown obstacles which require you to autonomously backtrack to the last fork and take an alternative route. A good indication of how tough this was is the fact that other (commercial) tele-operated robots, perhaps surprisingly, fared no better than their autonomous rivals. Having spent a cold couple of hours looking over the shoulders of 2 team members: one tele-operating his robot, the other (nervously) tracking his autonomous robot's progress on a laptop, it was clear to me that in an this environment tele-operation is - if anything - harder than autonomy. Or perhaps it would be fairer to say that neither tele-operation or autonomy is yet fully up to this kind of task.
I left ELROB wishing that my robotics research colleagues who never venture outside their labs could have witnessed this and, as I did, experience the harsh reality-check of real world robotics.
Thursday, April 29, 2010
EPSRC HOW? event
Spent a most interesting day today at EPSRC HQ in Swindon. I was one of several academics asked to come and exhibit their work to the staff of the EPSRC. The idea of the event was to enable all of the staff of the council to get an insight into the research that EPSRC funds when, in the normal course of events (I guess), only a relatively few would get to see that research - programme managers for instance.
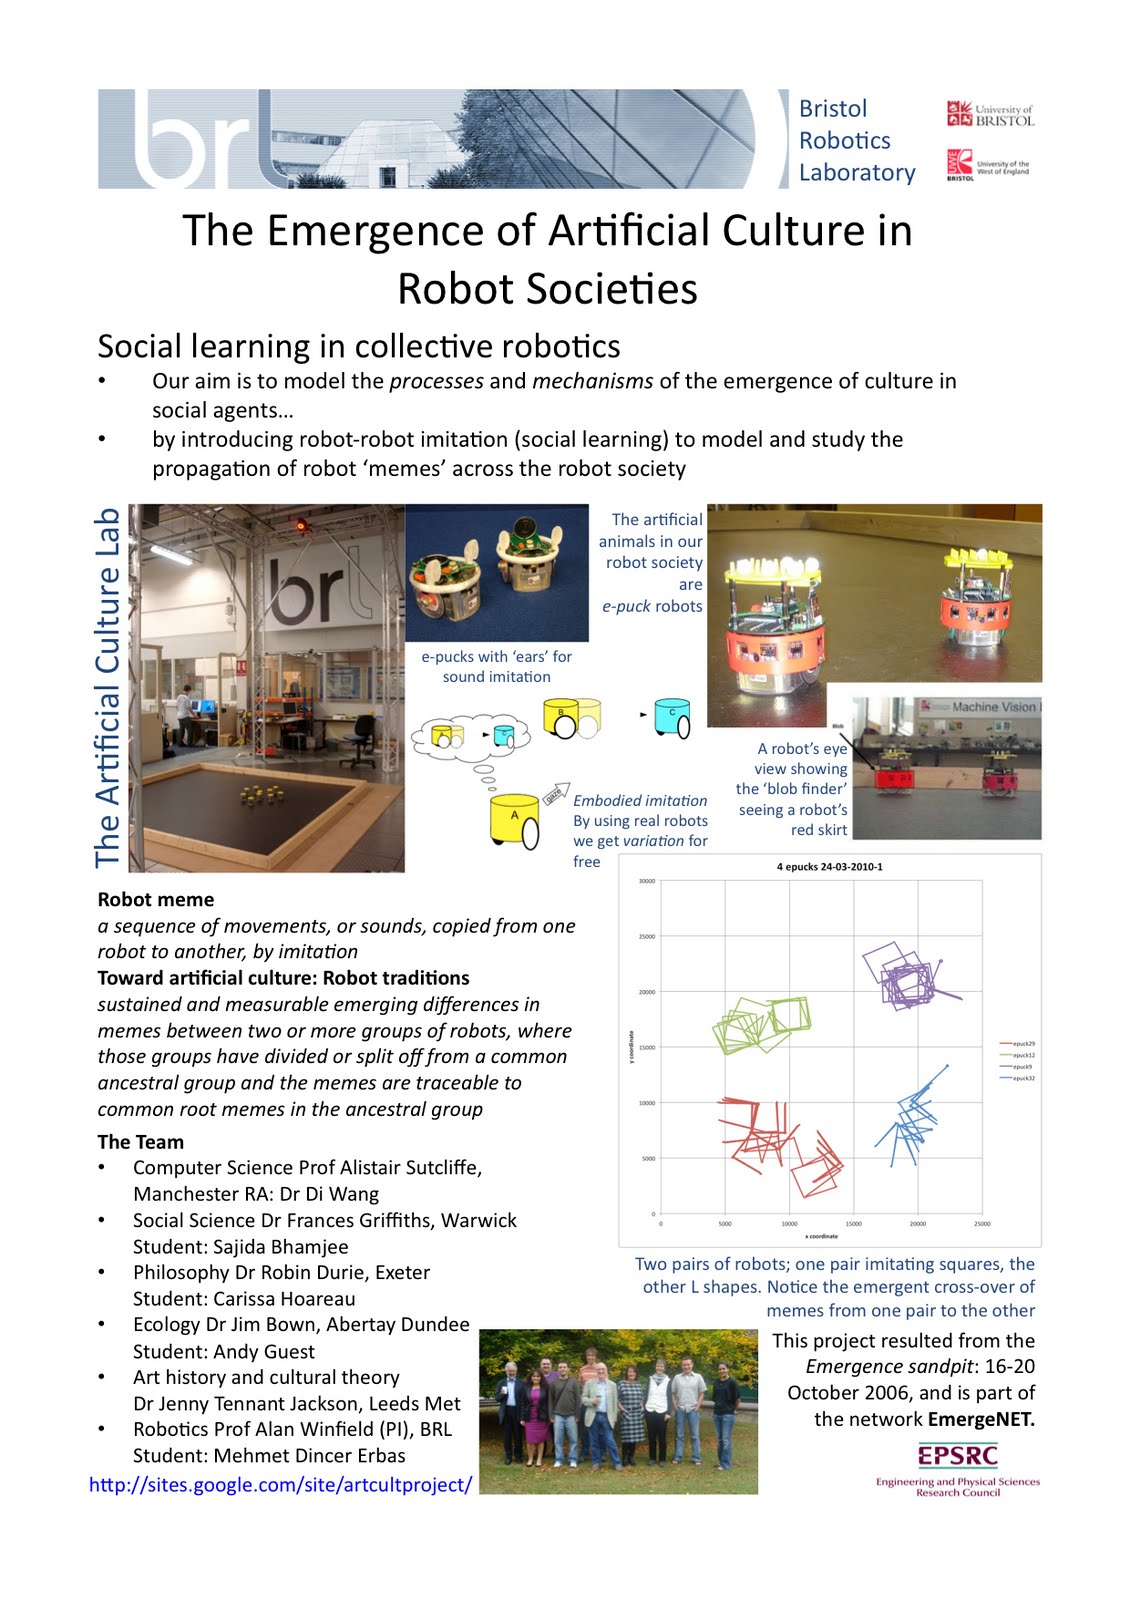
I took along some e-pucks and a portable arena, which proved very popular, together with this poster for the Artificial Culture project.

I took along some e-pucks and a portable arena, which proved very popular, together with this poster for the Artificial Culture project.
Friday, March 19, 2010
Expecting the expected on Mars
Learned something new and surprising about Mars rovers (like Spirit and Opportunity, and the planned European rover ExoMars): that if little green Martians jumped up and down in front of the Rover's cameras we almost certainly wouldn't know it. There are two reasons: firstly, the communications links between the Mars rovers and Earth are intermittent and low-bandwidth, so you can't have a live video stream (webcam) from the Rover to Earth and, secondly, the Rover's onboard cameras have image processing software that is programmed to look for specific things, like interesting rocks. This means that the Rover simply wouldn't 'see' the Martians, they are - in a sense - programmed to expect the expected. Although we are used to seeing the amazing panoramic views from the surface of Mars, these still images are only grabbed infrequently so our Martian would have to be standing in front of the Rover at precisely the moment the image is captured for us to see him (it).
I just spent 2 days with a remarkably interesting group of space scientists (planetary geology, exobiology, etc), space industry and roboticists discussing the science and engineering of Mars sample return missions: i.e. to find, collect and then bring interesting Mars rocks back to Earth. Given the immense cost and technical risk of mounting such a mission it seems to me worth the extra small effort of giving the rover(s) systems that would allow them (and us) to notice unexpected or unusual stuff. An image processing module that, for instance, continuously looks for things in the camera's view that are the wrong colour, or shape, moving in a different way to everything else. The whole point of exploration is that you don't know what's there and, while I'm not suggesting there really are Martians (other than perhaps microbes), it does seem to me that we should engineer systems that allow for the possibility of discovering the unexpected.
I just spent 2 days with a remarkably interesting group of space scientists (planetary geology, exobiology, etc), space industry and roboticists discussing the science and engineering of Mars sample return missions: i.e. to find, collect and then bring interesting Mars rocks back to Earth. Given the immense cost and technical risk of mounting such a mission it seems to me worth the extra small effort of giving the rover(s) systems that would allow them (and us) to notice unexpected or unusual stuff. An image processing module that, for instance, continuously looks for things in the camera's view that are the wrong colour, or shape, moving in a different way to everything else. The whole point of exploration is that you don't know what's there and, while I'm not suggesting there really are Martians (other than perhaps microbes), it does seem to me that we should engineer systems that allow for the possibility of discovering the unexpected.
Wednesday, March 10, 2010
Robotic Visions in Parliament
I've blogged before about the excellent Robotic Visions project and - yes I admit it - I have a soft spot for Visions: its where public engagement gets political. Yesterday that happened quite literally as Robotic Visions went to Parliament. Representatives from 3 of the schools who were involved in Visions conferences in Newcastle, Oxford and Bristol came, with their teachers, to the Houses of Parliament to present their visions to roboticists, industrialists and of course parliamentarians.
Here's what I said.
"Imagine personal robot instead of personal computer. Imagine in old age you could have a robot nurse. Your grandchildren a robot teddy, that talks to them, reads them a story, and keeps an eye on them at the same time. Right now these things are possibilities but would we - should we - want them?
Intelligent Robotics is a technology likely to impact every aspect of future life and society. Intelligent robots will - for example - change the way we treat illness and look after the elderly, how we run our homes and workplaces, how we manage our waste, harvest our crops or mine for resources and - I’m sorry to say - how we fight our wars. But as we build smarter robots the boundaries between robots as mere machines, and robots as friends or companions, will become blurred - raising new and challenging ethical questions. This may seem to be a statement of the obvious, but robotics technology will have a much greater impact on our children’s generation than on my generation.
So what is it that makes intelligent robots different to other technologies in a way that means we need to have special concerns about their future impact? It is - I suggest - two factors in combination. Firstly, agency - the ability to make decisions without human intervention. And secondly, the ability to draw an emotional response from humans. Right now we have plenty of machines with agency, within limits, like airline autopilots or room thermostats. We also have machines that generate emotional responses: Ferraris or iPods, for example. Intelligent robots are different because they bring these two elements together in a potent new combination that - frankly - we don’t yet fully understand.
It is, therefore, very important that our children should have the opportunity to understand what robots can and can’t do right now, and where intelligent robotics research is taking us. It is important that our children understand and debate the implications of robotics technology, and make their own minds up about how robots should, or should not, be used in society. And it is important that those views should be heard - and taken seriously – by robotics researchers, funders and policy makers.
I have been immensely impressed by the enthusiasm with which teenagers have engaged in the Robotic Visions Conferences. The views that they have expressed are articulate, serious and insightful, and - on behalf of the Robotics Visions project team - I invite you to consider those views and quotes in the summary paper and on the posters in this room, and to meet with their representatives here today."
Here's what I said.
"Imagine personal robot instead of personal computer. Imagine in old age you could have a robot nurse. Your grandchildren a robot teddy, that talks to them, reads them a story, and keeps an eye on them at the same time. Right now these things are possibilities but would we - should we - want them?
Intelligent Robotics is a technology likely to impact every aspect of future life and society. Intelligent robots will - for example - change the way we treat illness and look after the elderly, how we run our homes and workplaces, how we manage our waste, harvest our crops or mine for resources and - I’m sorry to say - how we fight our wars. But as we build smarter robots the boundaries between robots as mere machines, and robots as friends or companions, will become blurred - raising new and challenging ethical questions. This may seem to be a statement of the obvious, but robotics technology will have a much greater impact on our children’s generation than on my generation.
So what is it that makes intelligent robots different to other technologies in a way that means we need to have special concerns about their future impact? It is - I suggest - two factors in combination. Firstly, agency - the ability to make decisions without human intervention. And secondly, the ability to draw an emotional response from humans. Right now we have plenty of machines with agency, within limits, like airline autopilots or room thermostats. We also have machines that generate emotional responses: Ferraris or iPods, for example. Intelligent robots are different because they bring these two elements together in a potent new combination that - frankly - we don’t yet fully understand.
It is, therefore, very important that our children should have the opportunity to understand what robots can and can’t do right now, and where intelligent robotics research is taking us. It is important that our children understand and debate the implications of robotics technology, and make their own minds up about how robots should, or should not, be used in society. And it is important that those views should be heard - and taken seriously – by robotics researchers, funders and policy makers.
I have been immensely impressed by the enthusiasm with which teenagers have engaged in the Robotic Visions Conferences. The views that they have expressed are articulate, serious and insightful, and - on behalf of the Robotics Visions project team - I invite you to consider those views and quotes in the summary paper and on the posters in this room, and to meet with their representatives here today."
Monday, January 04, 2010
The Ethical Roboticist
I strongly believe that researchers in intelligent robotics, autonomous systems and AI can no longer undertake their research in a moral vacuum, regard their work as somehow ethically neutral, or as someone else's ethical problem.
Researchers, we, need to be much more concerned about both how our work affects society and how interactions with this technology affect individuals.
Right now researchers in intelligent robots, or AI, do not need to seek ethical approval for their projects (unless of course they involve clinical or human subject trials), so most robotics/AI projects in engineering and computer science fall outside any kind of ethical scrutiny. While I'm not advocating that this should change now, I do believe – especially if some of the more adventurous current projects come anywhere close to achieving their goals – that ethical approval for intelligent robotics/AI research might be a wise course of action within five years.
Let me now try and explain why, by defining four ethical problems.
1. The ethical problem of artificial emotions, or robots that are designed to solicit an emotional response from humans
Right now, in our lab in Bristol, is a robot that can look you in the eye and, when you smile, the robot smiles back. Of course there's nothing 'behind' this smile, it's just a set of motors pulling and pushing the artificial skin of the robot's face. But does the inauthenticity of the robot's artificial emotions abnegate the designer of any responsibility for a human's response to that robot? I believe it does not, especially if those humans are children or unsophisticated users.
Young people at a recent Robotic Visions conference concluded that “robots shouldn't have emotions but they should recognise them”.
A question I'm frequently asked when giving talks is “could robots have feelings?”. My answer is “no, but we can make robots that behave as if they have feelings”. I'm now increasingly of the view that it won't matter whether a future robot really has feelings or not.
On the horizon is robots with artificial theory of mind, a development that will only serve to deepen this ethical problem.
2. The problem of engineering ethical machines
Clearly for all sorts of applications intelligent robots will need to be programmed with rules of safe/acceptable behaviour (c.f. Asimov 'laws' of robotics). This is not so far fetched: Ron Arkin, roboticist at Georgia Tech has proposed the development of an artificial conscience for military robots.
Such systems are no longer just an engineering problem. In short it is no longer good enough to build an intelligent robot, we need to be able to build an ethical robot. And, I would strongly argue, if it is a robot with artificial emotions, or designed to provoke human emotional responses, that robot must also have artificial ethics.
3. The societal problem of correct ethical behaviour toward robot companions or robot pets
Right now many people think of robots as slaves: that's what the word means. But in many near term applications it will – I argue - be more appropriate to think of robots as companions. Especially if those robots - say in healthcare – even in a limited sense 'get to know' their human charges over a period of time.
Our society rightly abhors cruelty to animals. Is it possible to be cruel to a robot? Right now not really, but as soon as we have robot companions or pets, on which humans come to depend – and that's in the very near future – then those human dependents will certainly expect their robots to be treated with respect and dignity [perhaps even to be accorded (animal) rights]. Would they be wrong to expect this?
4. The ethical problem of engineering sentient machines
A contemporary German philosopher, Thomas Metzinger, has asserted that all research in intelligent systems should be stopped. His argument is that in trying to engineer artificial consciousness we will, unwittingly, create machines that are in effect disabled (simply because we can't go from insect to human level intelligence in one go). In effect – he argues - we could create AI that can experience suffering. Now his position is extreme, but it does I think illustrate the difficulty. In moving from simple automata that in no sense could be thought of as sentient to intelligent machines that simulate sentience we need to be mindful of the ethical minefield of engineering sentience.
In summary:
What is it that makes intelligent autonomous systems different to other technologies in a way that means we need to have special concerns about ethical and societal impacts? It is, I suggest two factors in combination. Firstly, agency. Secondly, the ability to elicit an emotional response or in extremis dependency from humans. Right now we have plenty of systems with agency, within proscribed limits, like airline autopilots or room thermostats. We also have machines that generate emotional responses: Ferraris or iPods. Intelligent robots are different because they bring these two elements together in a potent new combination.
This post is the text of the statement I prepared for the EPSRC Societal Impact Panel in November 2009.
Researchers, we, need to be much more concerned about both how our work affects society and how interactions with this technology affect individuals.
Right now researchers in intelligent robots, or AI, do not need to seek ethical approval for their projects (unless of course they involve clinical or human subject trials), so most robotics/AI projects in engineering and computer science fall outside any kind of ethical scrutiny. While I'm not advocating that this should change now, I do believe – especially if some of the more adventurous current projects come anywhere close to achieving their goals – that ethical approval for intelligent robotics/AI research might be a wise course of action within five years.
Let me now try and explain why, by defining four ethical problems.
1. The ethical problem of artificial emotions, or robots that are designed to solicit an emotional response from humans
Right now, in our lab in Bristol, is a robot that can look you in the eye and, when you smile, the robot smiles back. Of course there's nothing 'behind' this smile, it's just a set of motors pulling and pushing the artificial skin of the robot's face. But does the inauthenticity of the robot's artificial emotions abnegate the designer of any responsibility for a human's response to that robot? I believe it does not, especially if those humans are children or unsophisticated users.
Young people at a recent Robotic Visions conference concluded that “robots shouldn't have emotions but they should recognise them”.
A question I'm frequently asked when giving talks is “could robots have feelings?”. My answer is “no, but we can make robots that behave as if they have feelings”. I'm now increasingly of the view that it won't matter whether a future robot really has feelings or not.
On the horizon is robots with artificial theory of mind, a development that will only serve to deepen this ethical problem.
2. The problem of engineering ethical machines
Clearly for all sorts of applications intelligent robots will need to be programmed with rules of safe/acceptable behaviour (c.f. Asimov 'laws' of robotics). This is not so far fetched: Ron Arkin, roboticist at Georgia Tech has proposed the development of an artificial conscience for military robots.
Such systems are no longer just an engineering problem. In short it is no longer good enough to build an intelligent robot, we need to be able to build an ethical robot. And, I would strongly argue, if it is a robot with artificial emotions, or designed to provoke human emotional responses, that robot must also have artificial ethics.
3. The societal problem of correct ethical behaviour toward robot companions or robot pets
Right now many people think of robots as slaves: that's what the word means. But in many near term applications it will – I argue - be more appropriate to think of robots as companions. Especially if those robots - say in healthcare – even in a limited sense 'get to know' their human charges over a period of time.
Our society rightly abhors cruelty to animals. Is it possible to be cruel to a robot? Right now not really, but as soon as we have robot companions or pets, on which humans come to depend – and that's in the very near future – then those human dependents will certainly expect their robots to be treated with respect and dignity [perhaps even to be accorded (animal) rights]. Would they be wrong to expect this?
4. The ethical problem of engineering sentient machines
A contemporary German philosopher, Thomas Metzinger, has asserted that all research in intelligent systems should be stopped. His argument is that in trying to engineer artificial consciousness we will, unwittingly, create machines that are in effect disabled (simply because we can't go from insect to human level intelligence in one go). In effect – he argues - we could create AI that can experience suffering. Now his position is extreme, but it does I think illustrate the difficulty. In moving from simple automata that in no sense could be thought of as sentient to intelligent machines that simulate sentience we need to be mindful of the ethical minefield of engineering sentience.
In summary:
What is it that makes intelligent autonomous systems different to other technologies in a way that means we need to have special concerns about ethical and societal impacts? It is, I suggest two factors in combination. Firstly, agency. Secondly, the ability to elicit an emotional response or in extremis dependency from humans. Right now we have plenty of systems with agency, within proscribed limits, like airline autopilots or room thermostats. We also have machines that generate emotional responses: Ferraris or iPods. Intelligent robots are different because they bring these two elements together in a potent new combination.
This post is the text of the statement I prepared for the EPSRC Societal Impact Panel in November 2009.
Wednesday, December 16, 2009
Mimetic Factors in Health and Well-being
On Monday I gave a talk at an amazingly interesting workshop in Warwick. Part of a project called Mimetic Factors in Health and Well-being, the workshop brought together a very diverse range of disciplines: sociology, medicine, systems science and robotics (and I may have missed a few).
Project lead, Steve Fuller, gave a great talk which reflected on both memetics (pre-Dawkins), and mimesis in advertising and PR. I found myself being introduced first to French sociologist Gabriel Tarde who, who - according to Steve Fuller - first articulated the pivotal role of imitation in society. Then to contemporary French social and cognitive scientist, and by the looks of it all round genius, Dan Sperber. I can see that I have to add Sperber to my reading list!

Project lead, Steve Fuller, gave a great talk which reflected on both memetics (pre-Dawkins), and mimesis in advertising and PR. I found myself being introduced first to French sociologist Gabriel Tarde who, who - according to Steve Fuller - first articulated the pivotal role of imitation in society. Then to contemporary French social and cognitive scientist, and by the looks of it all round genius, Dan Sperber. I can see that I have to add Sperber to my reading list!

Friday, December 11, 2009
Can I have a robot for Christmas?
I was delighted to be asked to give the annual Christmas lecture to the Nottingham Medico Chirurgical society last night, in the medical school of the famous Queens Medical Centre, Nottingham. Founded in 1828 Nottingham Med-Chi, as they like to call themselves, is one of the oldest such societies in the UK. It was a great audience, with a healthy mix of children and very eminent medics who together kept me on my toes when it came to questions and answers.
In my talk I focus on the current strong convergence of biology and robotics, but in reflecting and speaking with the medics afterwards I was struck that the next big convergence in robotics (perhaps the next wave after biology) will be with medicine. As our understanding of the human body and its astonishingly complex processes and mechanisms deepens, then - in a sense - medicine becomes more like ultra precision engineering. And as robotics moves toward artificial life, then engineering robots becomes far removed from mechanical and electrical engineering and more like bio-medical engineering. For a good example look at the BRL's Ecobot III, with all of its plumbing and bio-chemistry. Hence the convergence I predict.
Postscript: the Notts Med-Chi society is very firmly in the 21st C: I discovered my Christmas lecture can be downloaded as a podcast on iTunes.
In my talk I focus on the current strong convergence of biology and robotics, but in reflecting and speaking with the medics afterwards I was struck that the next big convergence in robotics (perhaps the next wave after biology) will be with medicine. As our understanding of the human body and its astonishingly complex processes and mechanisms deepens, then - in a sense - medicine becomes more like ultra precision engineering. And as robotics moves toward artificial life, then engineering robots becomes far removed from mechanical and electrical engineering and more like bio-medical engineering. For a good example look at the BRL's Ecobot III, with all of its plumbing and bio-chemistry. Hence the convergence I predict.
Postscript: the Notts Med-Chi society is very firmly in the 21st C: I discovered my Christmas lecture can be downloaded as a podcast on iTunes.
Wednesday, November 25, 2009
Robot ethics at the EPSRC societal issues panel
Tough afternoon yesterday. Why? I'll come to that. Along with the other senior media fellows, I attended EPSRC's Societal Issues Panel, chaired by Robert Winston. Before getting the invitation I didn't know about this group, but came away very impressed with just how deeply serious EPSRC is about engaging with public attitudes and concerns about science research and the potential societal impact of its funded research programmes.
As the new boy there wasn't much I could contribute to the main session, when the panel wanted to hear from the senior media fellows about their experiences and what more, or differently, the panel could do in its work. But listening to the SMFs experiences was for me incredibly useful. It was like getting a master class from not one but a whole group of virtuosi, concentrated into two hours.
But the tough bit was to follow. Noel Sharkey and I had been asked to stay for another agenda item on the potential ethical and societal impact of intelligent robots, artificial intelligence and autonomous systems. Noel and I each gave short introductions to what we thought were the main issues and I focussed on the ethical questions raised by research in intelligent robotics - i.e. the ethical roboticist.
postscript: The Ethical Roboticist
As the new boy there wasn't much I could contribute to the main session, when the panel wanted to hear from the senior media fellows about their experiences and what more, or differently, the panel could do in its work. But listening to the SMFs experiences was for me incredibly useful. It was like getting a master class from not one but a whole group of virtuosi, concentrated into two hours.
But the tough bit was to follow. Noel Sharkey and I had been asked to stay for another agenda item on the potential ethical and societal impact of intelligent robots, artificial intelligence and autonomous systems. Noel and I each gave short introductions to what we thought were the main issues and I focussed on the ethical questions raised by research in intelligent robotics - i.e. the ethical roboticist.
postscript: The Ethical Roboticist
Saturday, November 07, 2009
e-pucks in Osaka

Gave some Walking with Robots talks at an elementary school today, in Ikeda Japan (near Osaka). The e-pucks were a great success with the children, and were joined by some amazing Japanese robots, like Paro - the robot seal. Pictures to follow...
Wednesday, October 21, 2009
The robots are coming (to Manchester)
 If you're in or around Manchester Saturday 24th - Tuesday 27th October, do come and see us at the Walking with Robots festival of robotics - part of the Manchester Science Festival.
Here are links to the events:
Subscribe to:
Posts (Atom)